
BrainCo Revo 3-21 Touch Review: 21-DOF Tactile Robot Hand for Embodied AI
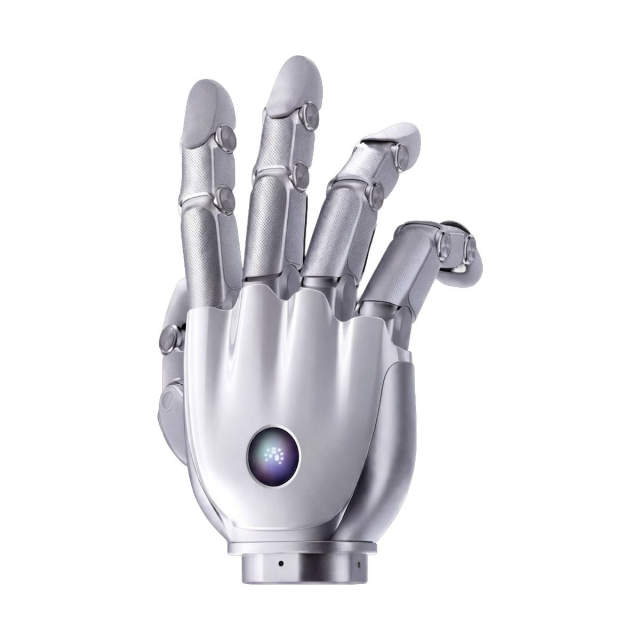
The BrainCo Revo 3-21 Touch is a 21-DoF dexterous robotic hand for embodied-AI research and contact-rich manipulation. Direct-drive joints, tactile sensing, 500 Hz control, and industrial interfaces make it technically ambitious, but it remains a specialist component requiring careful mechanical, electrical, and software integration.
Origin
China
Model
Revo 3-21 Touch
Robot Type
Dexterous tactile robotic hand / end-effector
Manufacturer
BrainCo
Release
April 2026
Degrees of Freedom
21 DOF
Joint Architecture
Fully direct-drive, backdrivable
Palm Tactile Sensing
Full-palm sensing; 0.01 N force resolution
Fingertip Sensing
Tactile + visuotactile; approximately 130 μm deformation detection
Control Frequency
500 Hz
Control Modes
Position, impedance, MIT force-position, zero-torque
Pinch Force
20 N
Open-Close Cycle Rate
3 Hz
Grasp Types
33 supported
Range of Motion
Exceeds typical human range in published Kapandji testing
Communication
EtherCAT, CAN FD, RS-485
Operating Voltage
12–80 V
Software
Python, C, ROS; Linux and Windows
Deployment
Open ecosystem; sim2real compatible; one-click deployment described by manufacturer
Price
$21,000
Warranty
12 months
Dexterous end-effector scope
BrainCo Revo 3-21 Touch is a 21-DOF tactile robotic hand for contact-rich manipulation research. Its listed direct-drive, backdrivable joints; palm and fingertip sensing; 500 Hz control loop; and EtherCAT, CAN FD and RS-485 interfaces set a notably more ambitious scope than a parallel gripper. The potential is in sensing and control experimentation, not a guaranteed production grasp.
Technical interpretation
Published force resolution, deformation detection, pinch force, cycle rate and grasp-count figures should be used as manufacturer specifications until verified in the buyer’s system. End-effector performance depends on arm compliance, object set, contact conditions, cable routing, controller tuning and task policy. “One-click deployment” and sim-to-real claims do not remove the need for integration engineering.
Integration diligence
Confirm mechanical adapter, mass and inertia, power supply, thermal limits, cable set, controller hardware, supported software versions, API licensing and spare-parts strategy. Request a load, durability and maintenance profile for the intended grasp set. Ensure machine safety and pinch-hazard controls are designed at the complete arm-cell level.
Acceptance test
Benchmark representative objects for grasp success, in-hand adjustment, contact-force stability, recovery after an object slip and performance over repeated cycles. Measure control latency and calculate the genuine integration time needed to move from demo to task.
Verdict
A compelling specialist research hand for teams ready to engineer tactile manipulation. For simple repeatable handling, a conventional gripper remains the lower-risk and lower-cost baseline.
Pros
Cons
Editorial Verdict
The Revo 3-21 Touch is relevant when a project requires tactile feedback and dexterous in-hand control. For simple gripping or high-throughput handling, a conventional end-effector will usually be easier to deploy and more economical.
Criteria Scores

BrainCo Revo 3-21 Touch Review: 21-DOF Tactile Robot Hand for Embodied AI